
A Robust and Reliable Vision-Language-Action Interface
We will improve the safety, reliability, and robustness of Vision–Language–Action (VLA) models for robot control by making them situation-, self-, and ambiguity-aware. Building on recent VLA/LRM advances and on our ELLIIT C08 results in out-of-distribution detection and uncertainty quantification, we will develop methods that fuse sensory input with reasoning, recognize when the robot operates outside its training regime, and detect/resolve language ambiguity. Our approach is novel in extending uncertainty handling from perception to multimodal planning and decision-making, and feasible because it leverages established open architectures and our prior, validated methods. The outcome is a trustworthy VLA interface that improves human–robot collaboration and accelerates safe adoption in industrial and societal applications.
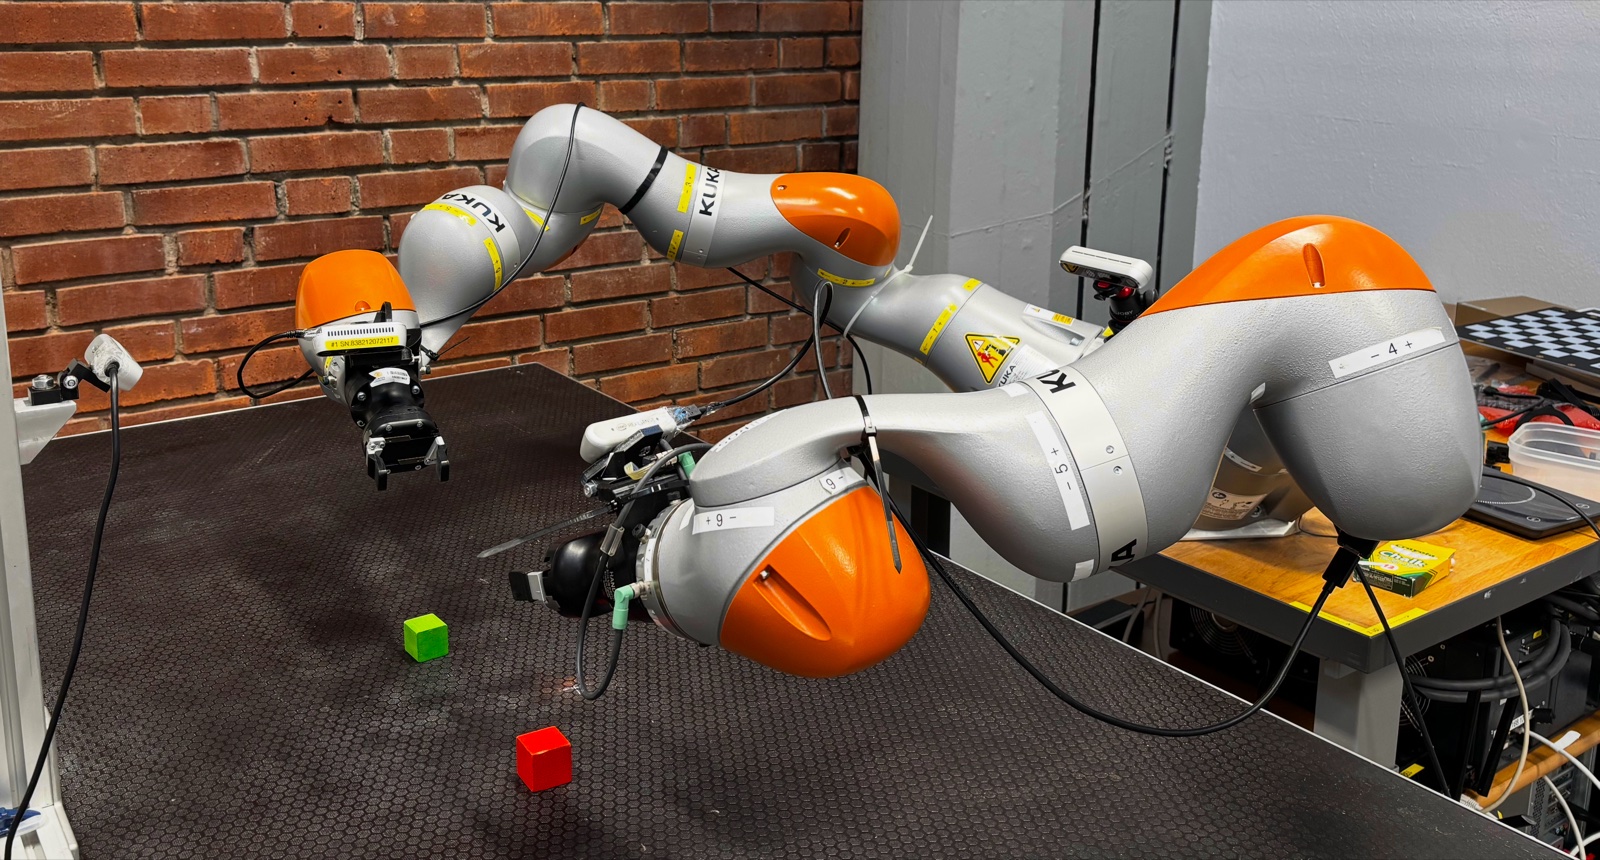
The project is funded by ELLIIT as a collaboration between Per-Erik Forssén at Linköping University and Volker Krueger at Lund University. Experiments at Lund use the robots in RobotLab LTH, including a dual-arm KUKA iiwa and UR5e manipulators.
At Lund, the project includes the doctoral project of Wenrui Xie, supervised by Volker Krueger, Maj Stenmark and Davide Tateo.
Last updated: 2026-11-10